Grasping with TurtleBot3 by keyboard operation †TurtleBot3 has OpenManipulator. Please refer to here for the specifications of Open Manipulator. Startup Procedure †Start the Ubuntu side and then the Windows side. Ubuntu side startup procedure †Open a new terminal and run the following command: $ roslaunch sigverse_turtlebot3_open_manipulator grasping_teleop_key.launch Windows startup procedure †Start the [Assets/SIGVerse/ExampleScenes/Turtlebot3/OpenManipulator(.unity)] scene with reference to here. Run †You can control TurtleBot3 by keyboard operation on the grasping_teleop_key.launch terminal. * Check the terminal for details of the operation. * Because of the high image processing load, the robot's camera image transmission interval is set to 1000 [ms]. If you want to finish, stop the Unity side and then the ROS side. Ubuntu side (The details may differ from the latest version) 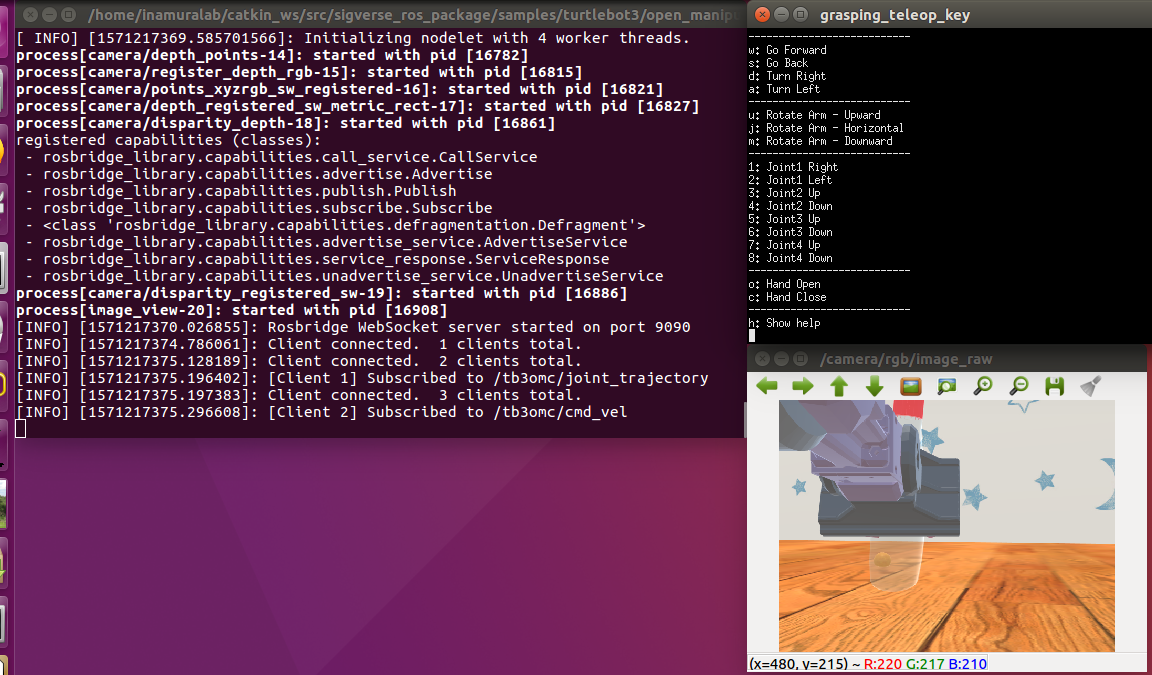 Windows side (The details may differ from the latest version) 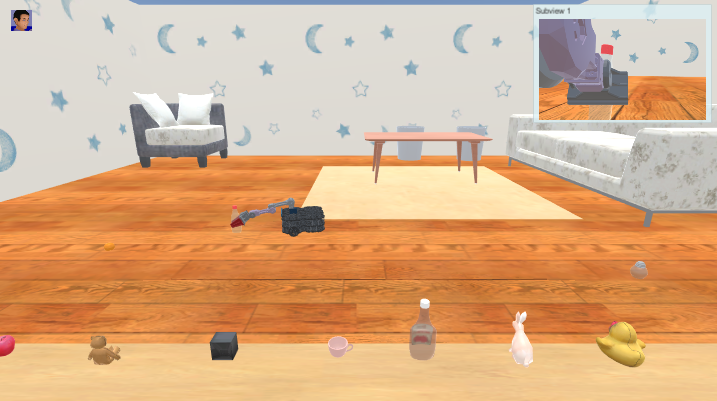 Reference Video |
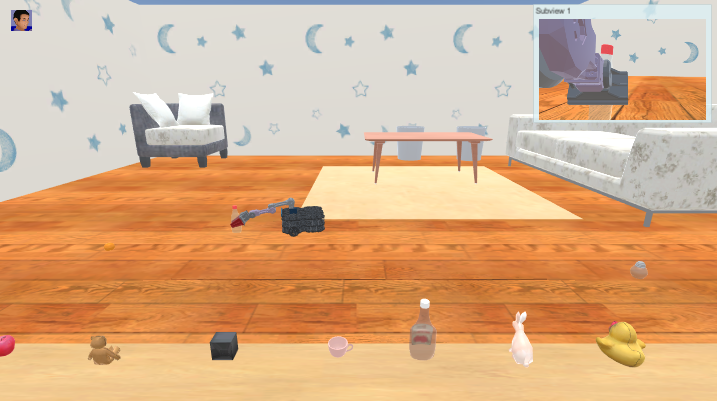 TurtleBot3GraspTeleopWindows.png 1547 download
[Information]
 TurtleBot3GraspTeleopUbuntu.png 1572 download
[Information]


Site admin: inamura
PukiWiki 1.5.0 Copyright © 2001-2006 PukiWiki Developers Team. License is GPL.
